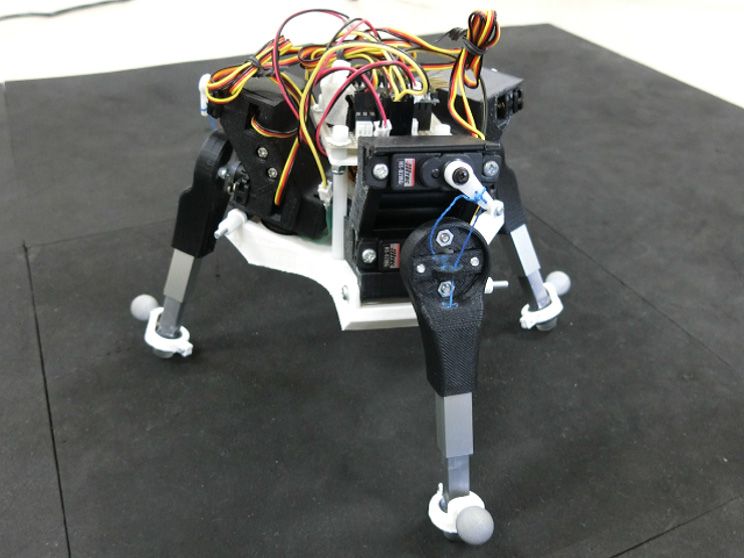
Martian Petit

Descript


When Yoichi Masuda set out to design a new legged robot, he found inspiration in the Martian Tripods from the classic sci-fi novel “The War of the Worlds” by H.G. Wells. A three-legged configuration seems to offer some advantages when it comes to walking and balancing, and Masuda became curious about the absence of three-legged animals in nature. Are there evolutionary factors that explain why we haven’t seen any? And if three-legged creatures existed, could there be a universal principle of walking locomotion, common for bipeds, tripeds, and quadrupeds? To explore those questions, Masuda and his colleagues at Osaka University built a three-legged robot named Martian.

Edit | Back to List

SpecificRobotsInRelation

Manage Relation
Property Category Properties
Contributing Fields Aerod | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | Aero | TEST | TEST | Aero | Aero | TEST | TEST | TEST | Aerod |
Degree of maturity TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 8. system complete and qualified | TRL 7. system prototype demonstration in operational environment | TRL 8. system complete and qualified | TRL 7. system prototype demonstration in operational environment | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 4. technology validated in lab | TRL 7. system prototype demonstration in operational environment | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 4. technology validated in lab | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 7. system prototype demonstration in operational environment | TRL 4. technology validated in lab | TRL 8. system complete and qualified | TRL 7. system prototype demonstration in operational environment | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 4. technology validated in lab | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 7. system prototype demonstration in operational environment | TRL 4. technology validated in lab | TRL 7. system prototype demonstration in operational environment | TRL 4. technology validated in lab | TRL 8. system complete and qualified | TRL 7. system prototype demonstration in operational environment | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 8. system complete and qualified | TRL 7. system prototype demonstration in operational environment | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 4. technology validated in lab | TRL 8. system complete and qualified | TRL 7. system prototype demonstration in operational environment | TRL 4. technology validated in lab | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 7. system prototype demonstration in operational environment | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 8. system complete and qualified | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 4. technology validated in lab | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 7. system prototype demonstration in operational environment | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 1. basic principles observed | TRL 2. technology concept formulated | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 8. system complete and qualified | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 7. system prototype demonstration in operational environment | TRL 2. technology concept formulated | TRL 2. technology concept formulated | TRL 6. technology demonstrated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 7. system prototype demonstration in operational environment | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 9. actual system proven in operational environment (competitive manufacturing in the case of key enabling technologies; or in space) | TRL 5. technology validated in relevant environment (industrially relevant environment in the case of key enabling technologies) | TRL 3. experimental proof of concept |
Branches Sensors | Sensors | Ant robotics | Robot locomotion | Robot locomotion | Intelligent vehicle technologies | Test BRanch | Intelligent vehicle technologies | Test BRanch | Remote surgery | Robot locomotion | Robot locomotion | Sensors | Sensors | Computer vision | Computer vision | Robot programming | Programming by Demonstration | Test | Test BRanch | Computer vision | Robot kinematics | Simultaneous localization and mapping | Simultaneous localization and mapping | Ant robotics | Passive dynamics | Rapid prototyping | Telepresence | Test | Reinforcement learning | Test | Test | Swarm robotics | Test | Robot kinematics | Telepresence | Remote surgery | Test | Telepresence | Test | Passive dynamics | Machine vision | Software engineering | Swarm robotics | Rapid prototyping | Test BRanch | Programming by Demonstration | Reinforcement learning | Test | Telepresence | Test | Software engineering | Test BRanch | Swarm robotics | Speech processing | Simultaneous localization and mapping | Test BRanch | Test BRanch | Speech processing | Simultaneous localization and mapping | Test BRanch | Passive dynamics | Test | Robot programming | Support vector machines | Ant robotics | Speech processing | Robotic surgery | Reinforcement learning | Test | Machine vision | Support vector machines | Remote surgery | Speech processing | Robot kinematics | Computer vision | Software engineering | Simultaneous localization and mapping | Remote surgery | Robot programming | Robotic surgery | Test | Support vector machines | Ant robotics | Rapid prototyping | Computer vision | Rapid prototyping | Reinforcement learning | Programming by Demonstration | Remote surgery | Swarm robotics | Robotic surgery | Test | Support vector machines | Swarm robotics | Ant robotics | Ubiquitous robotics | Computer vision | Passive dynamics | Test BRanch | Programming by Demonstration | Test | Test | Software engineering | Test | Robotic surgery | Ubiquitous robotics | Programming by Demonstration | Support vector machines | Ubiquitous robotics | Remote surgery | Test BRanch | Test BRanch | Robot programming | Robot kinematics | Machine vision | Swarm robotics | Robotic surgery | Ubiquitous robotics | Reinforcement learning | Software engineering | Reinforcement learning | Passive dynamics | Software engineering | Test | Simultaneous localization and mapping | Computer vision | Robotic surgery | Ant robotics | Robot programming | Passive dynamics | Test | Programming by Demonstration | Ubiquitous robotics | Programming by Demonstration | Speech processing | Ant robotics | Robot kinematics | Rapid prototyping | Test BRanch | Support vector machines | Remote surgery | Machine vision | Rapid prototyping | Machine vision | Telepresence | Ubiquitous robotics | Test BRanch | Test BRanch | Robot kinematics | Test | Support vector machines | Speech processing | Robot locomotion | Robot locomotion | Robot-assisted heart surgery | Simultaneous localization and mapping | Robot-assisted heart surgery | Robot-assisted heart surgery | Robot-assisted heart surgery | Robot kinematics | Sensors | Robot kinematics | Sensors | Test BRanch | Test BRanch | Robotic surgery | Robot-assisted heart surgery | Test BRanch | Swarm robotics | Sensors | Test BRanch | Ant robotics | Test BRanch | Intelligent vehicle technologies | Robotic surgery | Programming by Demonstration | Ubiquitous robotics | Robot locomotion | Simultaneous localization and mapping | Test | Robot-assisted heart surgery | Test BRanch | Computer vision | Simultaneous localization and mapping | Telepresence | Sensors | Rapid prototyping | Computer vision | Remote surgery | Sensors | Intelligent vehicle technologies | Robot locomotion | Software engineering | Test BRanch | Intelligent vehicle technologies | Robot kinematics | Robot-assisted heart surgery | Intelligent vehicle technologies | Test BRanch | Test | Robot-assisted heart surgery | Robot locomotion | Sensors | Intelligent vehicle technologies | Robot locomotion | Robot-assisted heart surgery | Programming by Demonstration | Telepresence | Test BRanch | Sensors | Remote surgery | Support vector machines | Robot locomotion | Sensors | Test BRanch | Test BRanch | Robot-assisted heart surgery | Robot locomotion | Passive dynamics | Robot-assisted heart surgery | Intelligent vehicle technologies | Test BRanch | Reinforcement learning | Test BRanch | Robot-assisted heart surgery | Test | Ubiquitous robotics | Robot locomotion | Swarm robotics | Reinforcement learning | Machine vision | Test | Robot programming | Speech processing | Machine vision | Intelligent vehicle technologies | Robot locomotion | Intelligent vehicle technologies | Test | Sensors | Test | Robot kinematics | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test | Rapid prototyping | Robot locomotion | Machine vision | Passive dynamics | Sensors | Ubiquitous robotics | Reinforcement learning | Programming by Demonstration | Intelligent vehicle technologies | Remote surgery | Robot programming | Robot locomotion | Robot-assisted heart surgery | Test BRanch | Test | Remote surgery | Ant robotics | Sensors | Passive dynamics | Test | Robot programming | Ant robotics | Intelligent vehicle technologies | Test BRanch | Remote surgery | Test BRanch | Intelligent vehicle technologies | Robot kinematics | Computer vision | Software engineering | Telepresence | Robot locomotion | Remote surgery | Sensors | Robot kinematics | Speech processing | Robotic surgery | Rapid prototyping | Swarm robotics | Support vector machines | Test BRanch | Test BRanch | Intelligent vehicle technologies | Intelligent vehicle technologies | Ant robotics | Computer vision | Speech processing | Rapid prototyping | Robotic surgery | Test | Robotic surgery | Intelligent vehicle technologies | Telepresence | Test BRanch | Test | Remote surgery | Simultaneous localization and mapping | Telepresence | Simultaneous localization and mapping | Ubiquitous robotics | Programming by Demonstration | Robot kinematics | Rapid prototyping | Telepresence | Test BRanch | Simultaneous localization and mapping | Programming by Demonstration | Programming by Demonstration | Robot programming | Remote surgery | Machine vision | Sensors | Robot kinematics | Ubiquitous robotics | Reinforcement learning | Test | Telepresence | Passive dynamics | Robot programming | Speech processing | Rapid prototyping | Machine vision | Test BRanch | Telepresence | Intelligent vehicle technologies | Rapid prototyping | Test | Ant robotics | Ubiquitous robotics | Telepresence | Rapid prototyping | Machine vision | Telepresence | Simultaneous localization and mapping | Passive dynamics | Test BRanch | Test | Passive dynamics | Support vector machines | Software engineering | Test BRanch | Test BRanch | Programming by Demonstration | Robot programming | Robot locomotion | Test BRanch | Remote surgery | Programming by Demonstration | Test | Remote surgery | Robot programming | Test BRanch | Simultaneous localization and mapping | Test BRanch | Test BRanch | Swarm robotics | Ant robotics | Test BRanch | Test BRanch | Swarm robotics | Swarm robotics | Programming by Demonstration | Support vector machines | Robot programming | Reinforcement learning | Computer vision | Intelligent vehicle technologies | Robotic surgery | Sensors | Support vector machines | Telepresence | Rapid prototyping | Simultaneous localization and mapping | Programming by Demonstration | Telepresence | Test | Reinforcement learning | Test BRanch | Test | Speech processing | Test | Test | Software engineering | Ubiquitous robotics | Test BRanch | Swarm robotics | Computer vision | Test | Machine vision | Rapid prototyping | Rapid prototyping | Test | Remote surgery | Test BRanch | Test | Robotic surgery | Test | Robotic surgery | Robot-assisted heart surgery | Test | Rapid prototyping | Swarm robotics | Test BRanch | Test BRanch | Machine vision | Reinforcement learning | Ant robotics | Intelligent vehicle technologies | Speech processing | Test | Software engineering | Telepresence | Computer vision | Test BRanch | Robotic surgery | Test BRanch | Test BRanch | Test | Test | Robot programming | Reinforcement learning | Robot-assisted heart surgery | Telepresence | Robot kinematics | Remote surgery | Ant robotics | Remote surgery | Speech processing | Test BRanch | Software engineering | Programming by Demonstration | Reinforcement learning | Swarm robotics | Ant robotics | Ubiquitous robotics | Simultaneous localization and mapping | Sensors | Speech processing | Robot-assisted heart surgery | Swarm robotics | Ubiquitous robotics | Robotic surgery | Test BRanch | Rapid prototyping | Test BRanch | Swarm robotics | Remote surgery | Computer vision | Ubiquitous robotics | Machine vision | Remote surgery | Swarm robotics | Speech processing | Test | Machine vision | Simultaneous localization and mapping | Simultaneous localization and mapping | Support vector machines | Ant robotics | Speech processing | Telepresence | Test | Robot programming | Computer vision | Robot-assisted heart surgery | Test | Test | Test BRanch | Robot programming | Simultaneous localization and mapping | Remote surgery | Swarm robotics | Reinforcement learning | Programming by Demonstration | Remote surgery | Programming by Demonstration | Programming by Demonstration | Support vector machines | Swarm robotics | Test | Software engineering | Software engineering | Swarm robotics | Test | Computer vision | Remote surgery | Software engineering | Robotic surgery | Robotic surgery | Computer vision | Machine vision | Programming by Demonstration | Robot programming | Telepresence | Ubiquitous robotics | Robotic surgery | Test | Software engineering | Test | Robot kinematics | Support vector machines | Test BRanch | Robotic surgery | Robot kinematics | Telepresence | Test | Computer vision | Support vector machines | Speech processing | Reinforcement learning | Computer vision | Machine vision | Simultaneous localization and mapping | Ant robotics | Ubiquitous robotics | Software engineering | Test | Reinforcement learning | Swarm robotics | Ant robotics | Computer vision | Simultaneous localization and mapping | Intelligent vehicle technologies | Test BRanch | Ubiquitous robotics | Robot locomotion | Ant robotics | Test | Machine vision | Test | Computer vision | Robot kinematics | Programming by Demonstration | Rapid prototyping | Robot programming | Robot locomotion | Test | Software engineering | Rapid prototyping | Simultaneous localization and mapping | Simultaneous localization and mapping | Robotic surgery | Remote surgery | Test | Robot kinematics | Test BRanch | Test | Test | Sensors | Remote surgery | Ubiquitous robotics | Speech processing | Ant robotics | Swarm robotics | Remote surgery | Programming by Demonstration | Robotic surgery | Ant robotics | Robot kinematics | Swarm robotics | Test | Reinforcement learning | Ant robotics | Speech processing | Machine vision | Rapid prototyping | Programming by Demonstration | Robot-assisted heart surgery | Sensors | Software engineering | Support vector machines | Telepresence | Test BRanch | Simultaneous localization and mapping | Support vector machines | Reinforcement learning | Test | Test BRanch | Robot programming | Robot kinematics | Sensors | Speech processing | Test | Test | Rapid prototyping | Swarm robotics | Test BRanch | Robot locomotion | Programming by Demonstration | Sensors | Support vector machines | Support vector machines | Machine vision | Robot locomotion | Speech processing | Telepresence | Software engineering | Software engineering | Robot programming | Robot programming | Machine vision | Test | Robot programming | Support vector machines | Ant robotics | Software engineering | Support vector machines | Sensors | Ubiquitous robotics | Reinforcement learning | Remote surgery | Ant robotics | Telepresence | Test | Ant robotics | Programming by Demonstration | Ubiquitous robotics | Reinforcement learning | Software engineering | Reinforcement learning | Robot kinematics | Simultaneous localization and mapping | Machine vision | Robotic surgery | Swarm robotics | Telepresence | Test BRanch | Robot kinematics | Robot programming | Ant robotics | Ubiquitous robotics | Support vector machines | Test BRanch | Robot programming | Test BRanch | Test | Test | Support vector machines | Robot programming | Rapid prototyping | Software engineering | Robot kinematics | Test | Speech processing | Robot kinematics | Swarm robotics | Robotic surgery | Ant robotics | Swarm robotics | Simultaneous localization and mapping | Programming by Demonstration | Robotic surgery | Computer vision | Programming by Demonstration | Rapid prototyping | Computer vision | Test BRanch | Robotic surgery | Software engineering | Rapid prototyping | Intelligent vehicle technologies | Test BRanch | Intelligent vehicle technologies | Machine vision | Intelligent vehicle technologies | Reinforcement learning | Robot programming | Machine vision | Robot-assisted heart surgery | Robot locomotion | Test | Test BRanch | Test | Test | Robot locomotion | Ubiquitous robotics | Test | Test | Speech processing | Ubiquitous robotics | Computer vision | Ant robotics | Test BRanch | Test | Reinforcement learning | Robot-assisted heart surgery | Speech processing | Robot kinematics | Sensors | Ubiquitous robotics | Robot kinematics | Robotic surgery | Test | Robotic surgery | Simultaneous localization and mapping | Machine vision | Speech processing | Test | Reinforcement learning | Ubiquitous robotics | Speech processing | Intelligent vehicle technologies | Test | Test | Computer vision | Computer vision | Robot-assisted heart surgery | Robot-assisted heart surgery | Robot kinematics | Robot locomotion | Reinforcement learning | Test BRanch | Test BRanch | Test BRanch | Machine vision | Computer vision | Test BRanch | Test BRanch | Software engineering | Speech processing | Computer vision | Support vector machines | Test BRanch | Test | Reinforcement learning | Support vector machines | Robot programming | Test | Software engineering | Robot locomotion | Test | Support vector machines | Machine vision | Test | Ubiquitous robotics | Rapid prototyping | Telepresence | Test BRanch | Rapid prototyping | Reinforcement learning | Reinforcement learning | Reinforcement learning | Reinforcement learning | Reinforcement learning | Reinforcement learning | Reinforcement learning | Reinforcement learning | Reinforcement learning | Reinforcement learning | Reinforcement learning | Reinforcement learning | Reinforcement learning | Reinforcement learning | Reinforcement learning | Reinforcement learning | Reinforcement learning | Reinforcement learning | Reinforcement learning | Reinforcement learning | Reinforcement learning | Reinforcement learning | Reinforcement learning | Reinforcement learning | Reinforcement learning | Programming by Demonstration | Programming by Demonstration | Programming by Demonstration | Programming by Demonstration | Programming by Demonstration | Programming by Demonstration | Programming by Demonstration | Programming by Demonstration | Programming by Demonstration | Programming by Demonstration | Programming by Demonstration | Programming by Demonstration | Programming by Demonstration | Programming by Demonstration | Programming by Demonstration | Programming by Demonstration | Programming by Demonstration | Programming by Demonstration | Programming by Demonstration | Programming by Demonstration | Programming by Demonstration | Programming by Demonstration | Programming by Demonstration | Programming by Demonstration | Programming by Demonstration | Programming by Demonstration | Robot kinematics | Robot kinematics | Robot kinematics | Robot kinematics | Robot kinematics | Robot kinematics | Robot kinematics | Robot kinematics | Robot kinematics | Robot kinematics | Robot kinematics | Robot kinematics | Robot kinematics | Robot kinematics | Robot kinematics | Robot kinematics | Robot kinematics | Robot kinematics | Robot kinematics | Robot kinematics | Robot kinematics | Robot kinematics | Robot kinematics | Robot kinematics | Robot kinematics | Robot locomotion | Robot locomotion | Robot locomotion | Robot locomotion | Robot locomotion | Robot locomotion | Robot locomotion | Robot locomotion | Robot locomotion | Robot locomotion | Robot locomotion | Robot locomotion | Robot locomotion | Robot locomotion | Robot locomotion | Robot locomotion | Robot locomotion | Robot locomotion | Robot locomotion | Robot locomotion | Robot locomotion | Rapid prototyping | Rapid prototyping | Rapid prototyping | Rapid prototyping | Rapid prototyping | Rapid prototyping | Rapid prototyping | Rapid prototyping | Rapid prototyping | Rapid prototyping | Rapid prototyping | Rapid prototyping | Rapid prototyping | Rapid prototyping | Rapid prototyping | Rapid prototyping | Rapid prototyping | Rapid prototyping | Rapid prototyping | Rapid prototyping | Rapid prototyping | Rapid prototyping | Robot programming | Robot programming | Robot programming | Robot programming | Robot programming | Robot programming | Robot programming | Robot programming | Robot programming | Robot programming | Robot programming | Robot programming | Robot programming | Robot programming | Robot programming | Robot programming | Robot programming | Robot programming | Robot programming | Robot programming | Sensors | Sensors | Sensors | Sensors | Sensors | Sensors | Sensors | Sensors | Sensors | Sensors | Sensors | Sensors | Sensors | Sensors | Sensors | Sensors | Sensors | Sensors | Sensors | Sensors | Sensors | Simultaneous localization and mapping | Simultaneous localization and mapping | Simultaneous localization and mapping | Simultaneous localization and mapping | Simultaneous localization and mapping | Simultaneous localization and mapping | Simultaneous localization and mapping | Simultaneous localization and mapping | Simultaneous localization and mapping | Simultaneous localization and mapping | Simultaneous localization and mapping | Simultaneous localization and mapping | Simultaneous localization and mapping | Simultaneous localization and mapping | Simultaneous localization and mapping | Simultaneous localization and mapping | Simultaneous localization and mapping | Simultaneous localization and mapping | Simultaneous localization and mapping | Simultaneous localization and mapping | Simultaneous localization and mapping | Software engineering | Software engineering | Software engineering | Software engineering | Software engineering | Software engineering | Software engineering | Software engineering | Software engineering | Software engineering | Software engineering | Software engineering | Software engineering | Software engineering | Software engineering | Software engineering | Speech processing | Speech processing | Speech processing | Speech processing | Speech processing | Speech processing | Speech processing | Speech processing | Speech processing | Speech processing | Speech processing | Speech processing | Speech processing | Speech processing | Speech processing | Speech processing | Speech processing | Speech processing | Speech processing | Support vector machines | Support vector machines | Support vector machines | Support vector machines | Support vector machines | Support vector machines | Robotic surgery | Robotic surgery | Robotic surgery | Robotic surgery | Robotic surgery | Robotic surgery | Robotic surgery | Robotic surgery | Robotic surgery | Robotic surgery | Robotic surgery | Remote surgery | Remote surgery | Remote surgery | Remote surgery | Remote surgery | Remote surgery | Remote surgery | Remote surgery | Remote surgery | Remote surgery | Remote surgery | Remote surgery | Remote surgery | Remote surgery | Remote surgery | Remote surgery | Robot-assisted heart surgery | Robot-assisted heart surgery | Robot-assisted heart surgery | Robot-assisted heart surgery | Robot-assisted heart surgery | Robot-assisted heart surgery | Robot-assisted heart surgery | Robot-assisted heart surgery | Robot-assisted heart surgery | Robot-assisted heart surgery | Robot-assisted heart surgery | Robot-assisted heart surgery | Robot-assisted heart surgery | Robot-assisted heart surgery | Robot-assisted heart surgery | Robot-assisted heart surgery | Robot-assisted heart surgery | Swarm robotics | Swarm robotics | Swarm robotics | Swarm robotics | Swarm robotics | Swarm robotics | Swarm robotics | Swarm robotics | Swarm robotics | Swarm robotics | Swarm robotics | Ant robotics | Ant robotics | Ant robotics | Ant robotics | Ant robotics | Ant robotics | Ant robotics | Ant robotics | Ant robotics | Ant robotics | Ant robotics | Ant robotics | Ant robotics | Ant robotics | Ant robotics | Ant robotics | Ant robotics | Ant robotics | Ant robotics | Ant robotics | Telepresence | Telepresence | Telepresence | Telepresence | Telepresence | Telepresence | Telepresence | Telepresence | Telepresence | Telepresence | Telepresence | Telepresence | Telepresence | Telepresence | Telepresence | Telepresence | Telepresence | Telepresence | Intelligent vehicle technologies | Intelligent vehicle technologies | Intelligent vehicle technologies | Intelligent vehicle technologies | Intelligent vehicle technologies | Intelligent vehicle technologies | Intelligent vehicle technologies | Intelligent vehicle technologies | Intelligent vehicle technologies | Intelligent vehicle technologies | Intelligent vehicle technologies | Intelligent vehicle technologies | Computer vision | Computer vision | Computer vision | Computer vision | Computer vision | Computer vision | Computer vision | Computer vision | Computer vision | Computer vision | Computer vision | Computer vision | Computer vision | Machine vision | Machine vision | Machine vision | Machine vision | Machine vision | Machine vision | Machine vision | Machine vision | Machine vision | Machine vision | Machine vision | Machine vision | Machine vision | Machine vision | Machine vision | Machine vision | Machine vision | Machine vision | Machine vision | Machine vision | Ubiquitous robotics | Test | Test | Test | Test | Test | Test | Test | Test | Test | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test BRanch | Test | Test | Test | Test | Test | Test | Test | Test | Test | Test | Test | Test | Test | Test | Test | Test | Test | Test | Test | Test | Test | Test | Test | Test | Test | Test | Test | Test | Test | Test | Test | Test | Test | Test | Test | Test | Programming by Demonstration | Robot kinematics | Robot kinematics | Electronic stability control | Electronic stability control | Electronic stability control | Electronic stability control | Electronic stability control | Electronic stability control | Electronic stability control | Electronic stability control | Electronic stability control | Electronic stability control | Motor control | Developmental robotics | Cloud robotics | Cloud robotics | Digital control | Direct manipulation interface | Feedback control and regulation | Developmental robotics | Dimensionality reduction | Feedback control and regulation | Dimensionality reduction | Degrees of freedom | Robot control | Electronic stability control | Digital image processing | Human robot interaction | Cloud robotics | Human–computer interaction | Robotic mapping | Clustering | Bionics | Bionics | Robotic mapping | Electronic stability control | Evolutionary computation | Feedback control and regulation | Digital control | Direct manipulation interface | Developmental robotics | Evolutionary robotics | Microrobotics | Nanorobotics | Nanorobotics | Clustering | Evolutionary robotics | Evolutionary computation | Human–computer interaction | Developmental robotics | Bionics | Feedback control and regulation | Flexible Distribution functions | Robot control | Bionics | Clustering | Bionics | Digital control | Digital control | Motion planning | Digital image processing | Evolutionary robotics | Biomorphic robotics | Robot control | Evolutionary robotics | Biomimetic | Robotics conventions | Motion planning | Evolutionary robotics | Robot learning | Direct manipulation interface | Robotic mapping | Distributed robotics | Evolutionary computation | Clustering | Bionics | Biomorphic robotics | Dimensionality reduction | Digital image processing | Nanorobotics | Clustering | Direct manipulation interface | Digital control | Electronic stability control | Distributed robotics | Motion planning | Evolutionary robotics | Human–computer interaction | Distributed robotics | Artificial neural networks | Nanorobotics | Evolutionary robotics | Nanorobotics | Evolutionary computation | Dimensionality reduction | Clustering | Cloud robotics | Electronic stability control | Robotic mapping | Biomorphic robotics | Nanorobotics | Bionics | Direct manipulation interface | Nanorobotics | Human–computer interaction | Evolutionary robotics | Motion planning | Digital image processing | Cloud robotics | Feedback control and regulation | Distributed robotics | Human–computer interaction | Evolutionary computation | Feedback control and regulation | Biomorphic robotics | Clustering | Dimensionality reduction | Human–computer interaction | Feedback control and regulation | Evolutionary robotics | Cloud robotics | Distributed robotics | Developmental robotics | Robotic mapping | Nanorobotics | Evolutionary robotics | Biomimetic | Distributed robotics | Aerial robotics | Clustering | Artificial intelligence | Robot control | Artificial neural networks | Dimensionality reduction | Robotic mapping | Artificial intelligence | Clustering | Artificial intelligence | Aerial robotics | Robot control | Dimensionality reduction | Degrees of freedom | Human–computer interaction | Robotics conventions | Adaptive control | Digital image processing | Bio-inspired robotics | Digital image processing | Developmental robotics | Kinematics | Developmental robotics | Robotic mapping | Cloud robotics | BEAM robotics | Laboratory robotics | Feedback control and regulation | Kinematics | Distributed robotics | Digital image processing | Robot control | Bio-inspired robotics | Cloud robotics | Artificial intelligence | Autonomous research robotics | Microrobotics | Robot control | Biorobotics | Laboratory robotics | Distributed robotics | Data mining Techniques | Feedback control and regulation | Artificial intelligence | Data mining Techniques | Bayesian network | Laboratory robotics | Autonomous car | Biomorphic robotics | Evolutionary robotics | Anthrobotics | Dimensionality reduction | Human–computer interaction | Bio-inspired robotics | Robot learning | Artificial neural networks | Microrobotics | Robotic mapping | Autonomous research robotics | Bayesian network | Robot learning | Bio-inspired robotics | Robot learning | Microrobotics | Anthrobotics | Laboratory robotics | Cognitive robotics | Kinematics | Nanorobotics | Bayesian network | Evolutionary robotics | Nanorobotics | Adaptive control | Robot control | Clustering | Artificial neural networks | Flexible Distribution functions | Robotic mapping | Data mining Techniques | Adaptive control | Artificial neural networks | Laboratory robotics | Direct manipulation interface | Biomorphic robotics | Behavior-based robotics | Biomimetic | Clustering | Distributed robotics | Autonomous research robotics | Evolutionary robotics | Biomimetic | Biomorphic robotics | Bayesian network | Direct manipulation interface | Adaptive control | Evolutionary computation | Manifold learning | Artificial intelligence | Robot learning | Human robot interaction | Bionics | Digital control | Autonomous research robotics | Bayesian network | Direct manipulation interface | Clustering | Motion planning | Adaptive control | Human–computer interaction | Developmental robotics | Microrobotics | Evolutionary robotics | Nanorobotics | Robotics conventions | Android science | Manifold learning | Biomimetic | BEAM robotics | Autonomous research robotics | Anthrobotics | Dimensionality reduction | Autonomous car | Human robot interaction | Robotics conventions | Evolutionary computation | Clustering | Distributed robotics | Aerial robotics | Evolutionary computation | Clustering | Biorobotics | Developmental robotics | Anthrobotics | Evolutionary computation | Manifold learning | Robot learning | Nanorobotics | Autonomous car | Data mining Techniques | Manifold learning | Aerial robotics | Bayesian network | Human–computer interaction | Android science | Distributed robotics | Robot control | Human–computer interaction | Dimensionality reduction | Evolutionary computation | Robotics conventions | Feedback control and regulation | Adaptive control | Aerial robotics | Electronic stability control | Bayesian network | Electronic stability control | Evolutionary robotics | Microrobotics | Robot control | Clustering | Bionics | Degrees of freedom | Clustering | Robot learning | Human robot interaction | Bionics | Bayesian network | Flexible Distribution functions | Laboratory robotics | Feedback control and regulation | Nanorobotics | Motion planning | Cognitive robotics | Dimensionality reduction | Autonomous research robotics | Dimensionality reduction | Bionics | Bayesian network | Data mining Techniques | Manifold learning | Motor control | Motor control | Evolutionary computation | Evolutionary computation | Dimensionality reduction | Flexible Distribution functions | Cognitive robotics | Clustering | Artificial intelligence | Android science | Robotics conventions | Autonomous car | Direct manipulation interface | Feedback control and regulation | Feedback control and regulation | Clustering | Behavior-based robotics | Cognitive robotics | Robot learning | Clustering | Degrees of freedom | Clustering |
Business | | | | | | | | | | | | | | | | | | | | | | | | | | | | | | | | | | | | | | | | | | | | | |
Influantial People Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle | Mösle |
Modes of Locomotion Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion | Locomotion |
Robotics Components And Design Features Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller | Propeller |
Robotics Companies
Robotics Competitions Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion | Robotic Competetion |
Development and Development Tools Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino | Arduino |
Robotics Organizations NCCR Robotics | NCCR Robotics | NCCR Robotics | Multi-Scale Robotics Laboratory | NCCR Robotics | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | NCCR Robotics | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | NCCR Robotics | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | 1 | RoMeLa | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | NCCR Robotics | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | NCCR Robotics | NCCR Robotics | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory | Multi-Scale Robotics Laboratory |
Robotic Principles Three Laws of Robotics | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Emergent behaviour | Emergent behaviour | Envelope (Space), Maximum | Envelope (Space), Maximum | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Artificial intelligence | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Emergent behaviour | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Envelope (Space), Maximum | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Humanoid | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Roboethics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Three Laws of Robotics | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Uncanny valley | Degrees of freedom | Degrees of freedom | Degrees of freedom | Degrees of freedom | Humanoid | Tool Center Point (TCP) | Tool Center Point (TCP) | Tool Center Point (TCP) |
Types Industrial robots | Industrial robots | Industrial robots | Industrial robots | Industrial robots | Industrial robots | Industrial robots | Industrial robots | Industrial robots | Industrial robots | Industrial robots | Industrial robots | Industrial robots | Industrial robots | Industrial robots | Industrial robots | Industrial robots | Industrial robots | Domestic or household robots | Domestic or household robots | Domestic or household robots | Domestic or household robots | Domestic or household robots | Domestic or household robots | Domestic or household robots | Domestic or household robots | Domestic or household robots | Domestic or household robots | Domestic or household robots | Domestic or household robots | Domestic or household robots | Domestic or household robots | Domestic or household robots | Domestic or household robots | Domestic or household robots | Domestic or household robots | Medical robots | Medical robots | Medical robots | Medical robots | Medical robots | Medical robots | Medical robots | Medical robots | Medical robots | Medical robots | Medical robots | Medical robots | Medical robots | Medical robots | Medical robots | Medical robots | Medical robots | Medical robots | Service robots | Service robots | Service robots | Service robots | Service robots | Service robots | Service robots | Service robots | Service robots | Service robots | Service robots | Service robots | Service robots | Military robots | Military robots | Military robots | Military robots | Military robots | Military robots | Military robots | Military robots | Military robots | Military robots | Military robots | Military robots | Military robots | Military robots | Military robots | Military robots | Military robots | Military robots | Entertainment robots | Entertainment robots | Entertainment robots | Entertainment robots | Entertainment robots | Entertainment robots | Entertainment robots | Entertainment robots | Entertainment robots | Entertainment robots | Entertainment robots | Entertainment robots | Entertainment robots | Entertainment robots | Entertainment robots | Entertainment robots | Entertainment robots | Entertainment robots | Space robots | Space robots | Space robots | Space robots | Space robots | Space robots | Space robots | Space robots | Space robots | Space robots | Space robots | Space robots | Space robots | Space robots | Space robots | Space robots | Space robots | Space robots | Hobby and competition robots | Hobby and competition robots | Hobby and competition robots | Hobby and competition robots | Hobby and competition robots | Hobby and competition robots | Hobby and competition robots | Hobby and competition robots | Hobby and competition robots | Hobby and competition robots | Hobby and competition robots | Hobby and competition robots | Hobby and competition robots | Hobby and competition robots | Hobby and competition robots | Hobby and competition robots | Hobby and competition robots | Hobby and competition robots | Stationary robots | Stationary robots | Stationary robots | Stationary robots | Stationary robots | Stationary robots | Stationary robots | Stationary robots | Stationary robots | Stationary robots | Stationary robots | Stationary robots | Stationary robots | Stationary robots | Stationary robots | Stationary robots | Stationary robots | Stationary robots | Cartesian/Gantry robots | Cartesian/Gantry robots | Cartesian/Gantry robots | Cartesian/Gantry robots | Cartesian/Gantry robots | Cartesian/Gantry robots | Cartesian/Gantry robots | Cartesian/Gantry robots | Cartesian/Gantry robots | Cartesian/Gantry robots | Cartesian/Gantry robots | Cartesian/Gantry robots | Cartesian/Gantry robots | Cartesian/Gantry robots | Cartesian/Gantry robots | Cartesian/Gantry robots | Cylindrical robot type | Cylindrical robot type | Cylindrical robot type | Cylindrical robot type | Cylindrical robot type | Cylindrical robot type | Cylindrical robot type | Cylindrical robot type | Cylindrical robot type | Cylindrical robot type | Cylindrical robot type | Spherical robots | Spherical robots | Spherical robots | Spherical robots | Spherical robots | Spherical robots | Spherical robots | Spherical robots | Spherical robots | Spherical robots | Spherical robots | Industrial robots | Industrial robots | Industrial robots | Industrial robots | Industrial robots | Industrial robots | Industrial robots | Industrial robots | Industrial robots | Industrial robots | Industrial robots | Industrial robots | Industrial robots | Domestic or household robots | Domestic or household robots | Domestic or household robots | Domestic or household robots | Domestic or household robots | Domestic or household robots | Domestic or household robots | Domestic or household robots | Domestic or household robots | Domestic or household robots | Domestic or household robots | Domestic or household robots | Domestic or household robots | Medical robots | Medical robots | Medical robots | Military robots | Military robots | Military robots | Military robots | Entertainment robots | Entertainment robots | Entertainment robots | Entertainment robots | Space robots | Space robots | Space robots | Stationary robots | Stationary robots | Stationary robots | Stationary robots | Industrial robots | Industrial robots | Industrial robots | Domestic or household robots | Domestic or household robots | Domestic or household robots | Domestic or household robots | Domestic or household robots | Domestic or household robots | Domestic or household robots |

Sources

+ Sources | Manage Sources

Ackerman, Evan : Martian-Inspired Tripod Walking Robot Generates Its Own Gaits. 8/7/2017 12:00:00 AM http://spectrum.ieee.org/automaton/robotics/robotics-hardware/martian-inspired-tripod-walking-robot-generates-its-own-gaits (8/15/2017 12:00:00 AM). [Link]