E-puck mobile robot [EN]
|
The e-puck is a small (7 cm) differential wheeled mobile robot. It was originally designed for micro-engineering education by Michael Bonani and Francesco Mondada at the ASL laboratory of Prof. Roland Siegwart at EPFL (Lausanne, Switzerland). The e-puck is open hardware and its onboard software is open source, and is built[1] and sold[2] by several companies.
https://en.wikipedia.org/wiki/E-puck_mobile_robot
|
EN |
1 |
Edit
Details
Delete
|
Create Relation
Manage Relation
Create Translation
|
Alice mobile robot [EN]
Alice mobile robot [DE]
|
The Alice is a very small "sugarcube" mobile robot (2x2x2cm) developed at the Autonomous Systems Lab (ASL) at the EPFL in Lausanne, Switzerland between 1998 and 2004. It has been part of the Institute of Robotics and Intelligent Systems (IRIS) at ETH Zurich since 2006.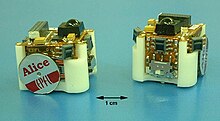
https://en.wikipedia.org/wiki/Alice_mobile_robot
|
EN |
2 |
Edit
Details
Delete
|
Create Relation
Manage Relation
Create Translation
Modify DE
|
Martian Petit [EN]
Martian Petit [DE]
|
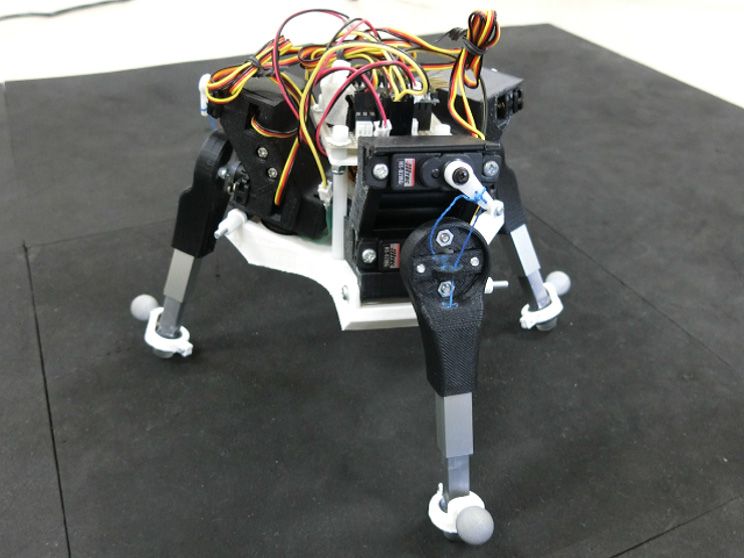
When Yoichi Masuda set out to design a new legged robot, he found inspiration in the Martian Tripods from the classic sci-fi novel “The War of the Worlds” by H.G. Wells. A three-legged configuration seems to offer some advantages when it comes to walking and balancing, and Masuda became curious about the absence of three-legged animals in nature. Are there evolutionary factors that explain why we haven’t seen any? And if three-legged creatures existed, could there be a universal principle of walking locomotion, common for bipeds, tripeds, and quadrupeds? To explore those questions, Masuda and his colleagues at Osaka University built a three-legged robot named Martian.
|
EN |
3 |
Edit
Details
Delete
|
Create Relation
Manage Relation
Create Translation
Modify DE
|
|
|
|
|
|
|
Create Relation
Manage Relation
Create Translation
|
|
|
|
|
|
|
Create Relation
Manage Relation
Create Translation
|
|
|
|
|
|
|
Create Relation
Manage Relation
Create Translation
|
|
|
|
|
|
|
Create Relation
Manage Relation
Create Translation
|
|
|
|
|
|
|
Create Relation
Manage Relation
Create Translation
|
|
|
|
|
|
|
Create Relation
Manage Relation
Create Translation
|
|
|
|
|
|
|
Create Relation
Manage Relation
Create Translation
|
|
|
|
|
|
|
Create Relation
Manage Relation
Create Translation
|
|
|
|
|
|
|
Create Relation
Manage Relation
Create Translation
|
|
|
|
|
|
|
Create Relation
Manage Relation
Create Translation
|
|
|
|
|
|
|
Create Relation
Manage Relation
Create Translation
|
|
|
|
|
|
|
Create Relation
Manage Relation
Create Translation
|
|
|
|
|
|
|
Create Relation
Manage Relation
Create Translation
|
|
|
|
|
|
|
Create Relation
Manage Relation
Create Translation
|
|
|
|
|
|
|
Create Relation
Manage Relation
Create Translation
|
|
|
|
|
|
|
Create Relation
Manage Relation
Create Translation
|
|
|
|
|
|
|
Create Relation
Manage Relation
Create Translation
|
|
|
|
|
|
|
Create Relation
Manage Relation
Create Translation
|
|
|
|
|
|
|
Create Relation
Manage Relation
Create Translation
|
|
|
|
|
|
|
Create Relation
Manage Relation
Create Translation
|
|
|
|
|
|
|
Create Relation
Manage Relation
Create Translation
|
|
|
|
|
|
|
Create Relation
Manage Relation
Create Translation
|
|
|
|
|
|
|
Create Relation
Manage Relation
Create Translation
|
|
|
|
|
|
|
Create Relation
Manage Relation
Create Translation
|
|
|
|
|
|
|
Create Relation
Manage Relation
Create Translation
|
|
Geronimo (D) [DE]
|
|
|
|
|
Create Relation
Manage Relation
Create Translation
|
|
|
|
|
|
|
Create Relation
Manage Relation
Create Translation
|
|
|
|
|
|
|
Create Relation
Manage Relation
Create Translation
|

